Liquid Metal 3D Printer
A modified FDM platform for direct-write fabrication of liquid-metal strain sensors, with custom ROS 2 controls, registration, and automated testing.
- Built with
- ROS 2, Python, wxPython, C/C++ firmware, Prusa i3 MK3S+, Nordson Ultimus V, Dynamixel
- My role
- Software, controls, and test automation
- Status
- Research project, ARTS Lab
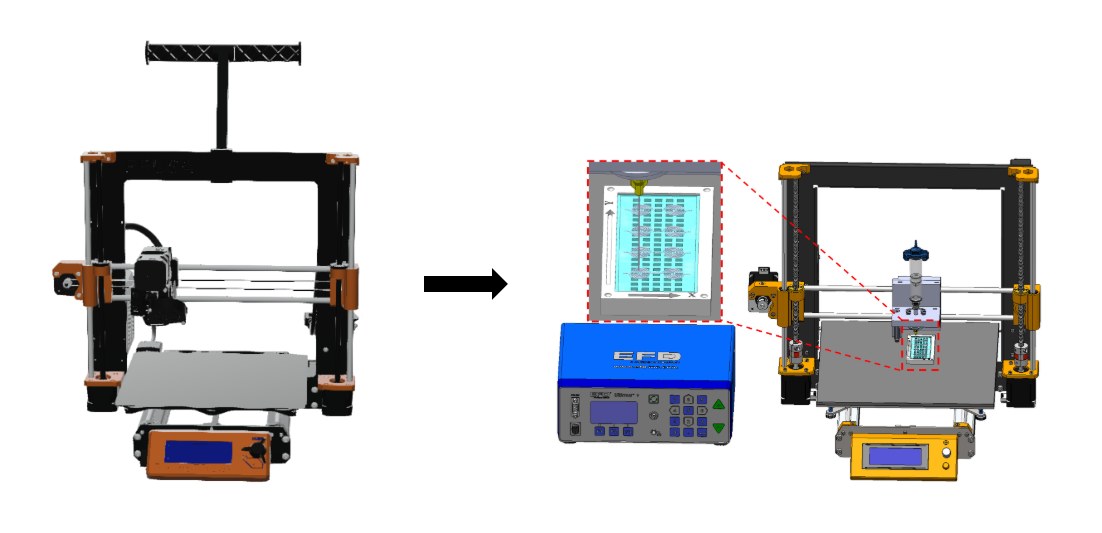
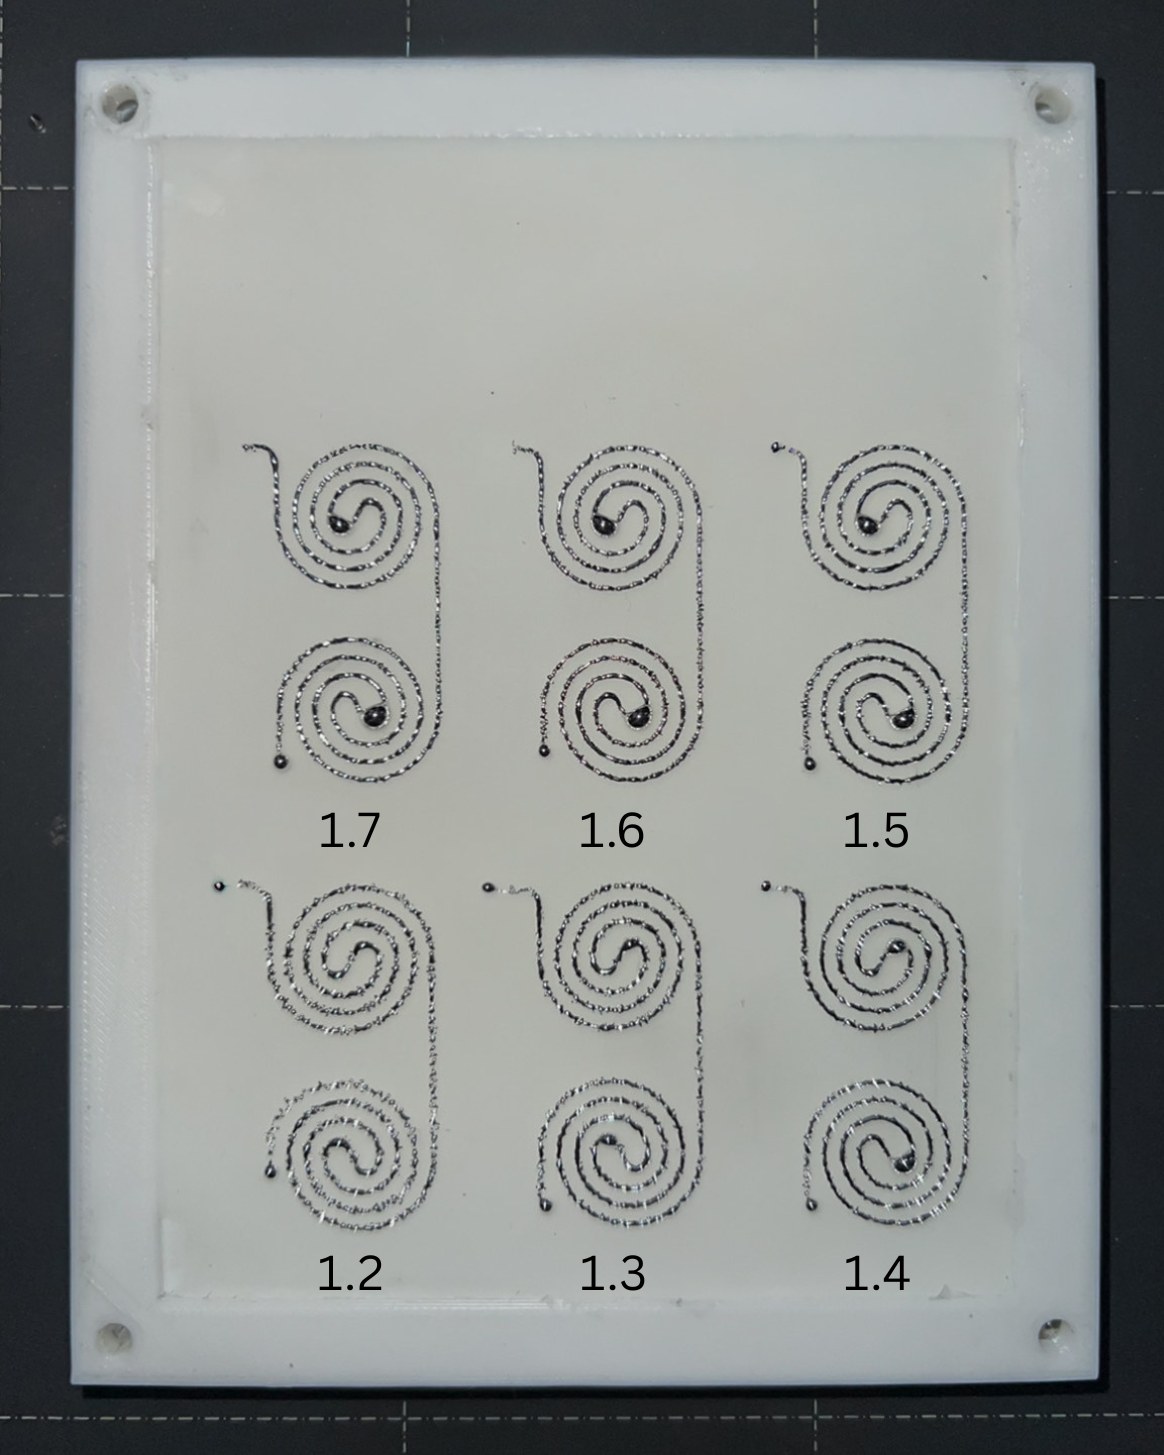
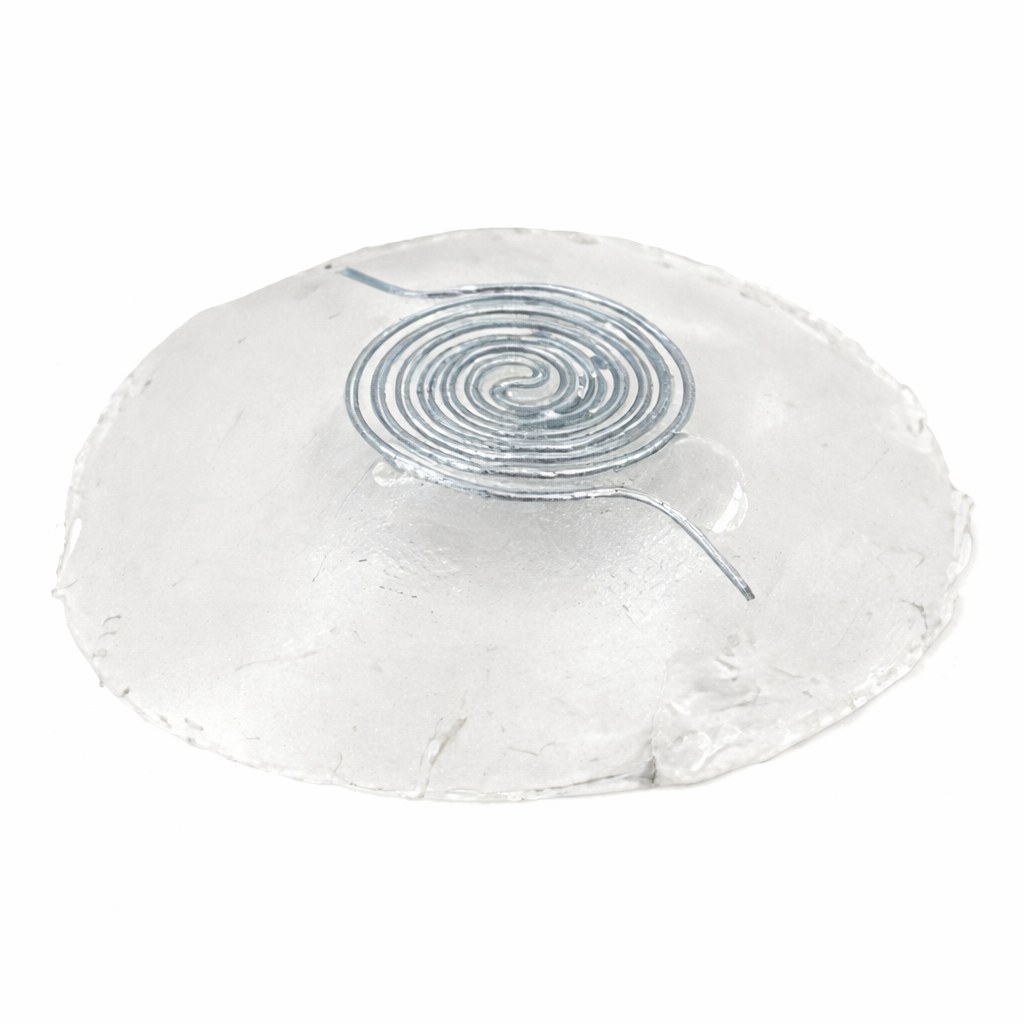
I developed the software and control stack for a modified Prusa i3 MK3S+ used to fabricate stretchable liquid-metal strain sensors. The system deposits conductive gallium traces directly onto silicone, allowing sensor geometries to be changed through software rather than requiring new mold tooling for each design.
My work included the ROS 2 control architecture, printer and pneumatic dispenser integration, operator interface, mold registration, firmware modifications, process calibration, and automated sensor characterization.
Control Architecture
I designed a ROS 2 architecture that separates printer motion, pneumatic dispensing, and user control into independent nodes. This keeps hardware communication and timing out of the GUI and allows each subsystem to run without blocking the others.
The printer node owns the Prusa serial connection, executes G-code, applies registration transforms, and handles printer responses through a dedicated reader thread. The dispenser node communicates with the Nordson Ultimus V and manages pressure, vacuum, and dispensing commands. A wxPython interface communicates with both through ROS topics and services.

One challenge was synchronizing material flow with printer motion. Serial commands to the pneumatic dispenser introduced enough delay that extrusion could begin after the nozzle had already started moving. I moved the timing-critical start and stop control onto the printer itself using a hardware trigger driven directly from the G-code, allowing dispensing to stay synchronized with the motion sequence.
Registration and Operator Interface
I built a wxPython interface for jogging and homing the printer, controlling the dispenser, adjusting process parameters, loading toolpaths, handling emergency stops, and previewing prints before execution.
I also developed a registration workflow for aligning generated toolpaths with the physical silicone mold. The operator records four reference points and a starting position, and the software computes the coordinate transformation used during printing. Registration profiles can be saved and reused between setups.
This reduced setup time by approximately 70%.

Firmware and Process Calibration
The original Prusa firmware was designed for thermoplastic extrusion, so I modified the Marlin C/C++ firmware and machine configuration for syringe-based gallium printing. This included integrating the custom hardware, adapting temperature control and safety behavior, and tuning motion parameters for the heavier toolhead.
Print quality depends on feed rate, pneumatic pressure, nozzle height, and dispensing timing. I developed calibration patterns and parameter sweeps to identify operating conditions that produced continuous traces without excessive pooling or breaks.
I also adjusted the printing sequence and motion profiles to reduce artifacts at starts, stops, and layer transitions.
Automated Sensor Characterization
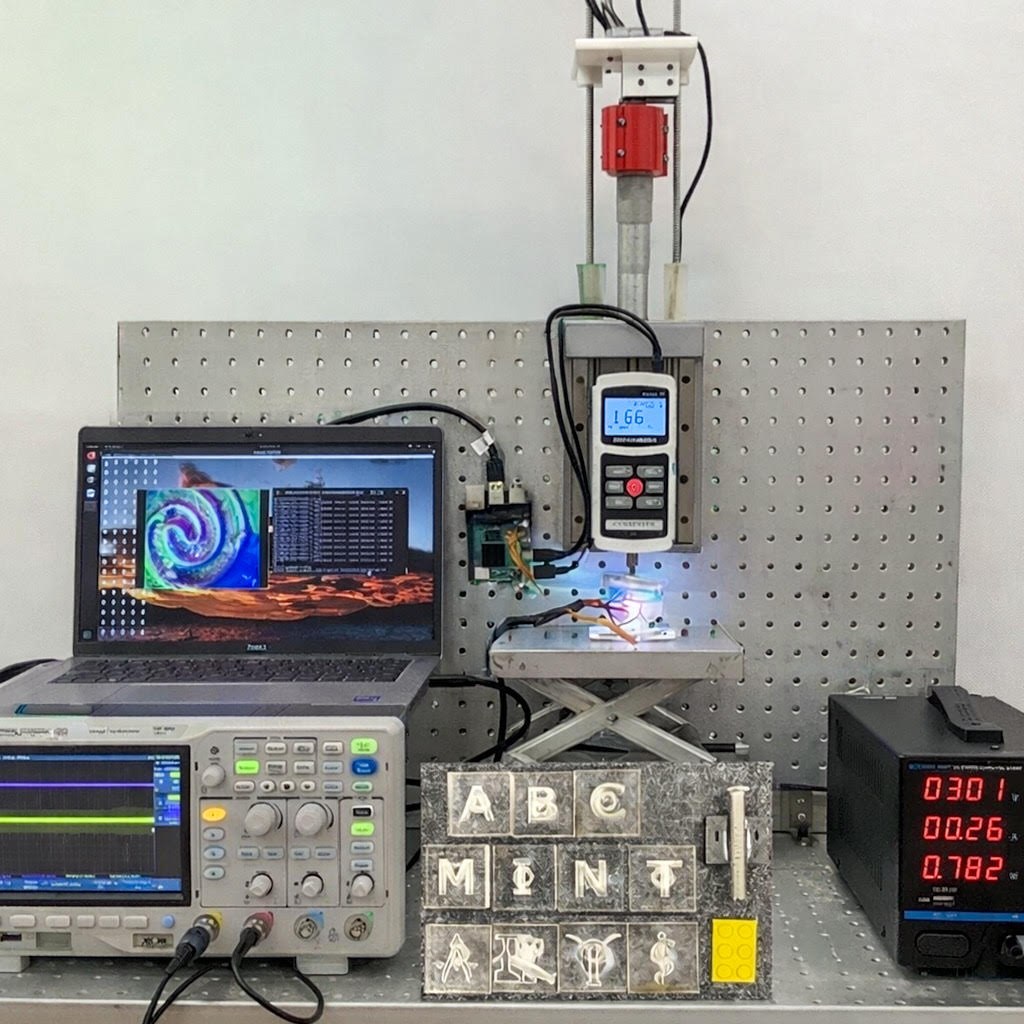
I developed Python tooling to automate testing of the fabricated sensors. A Dynamixel-driven test rig applies repeatable displacement profiles while force and electrical resistance are recorded together.
The automated workflow replaces manual testing and makes repeated trials easier to compare by synchronizing the mechanical and electrical measurements on a common timeline.
Application
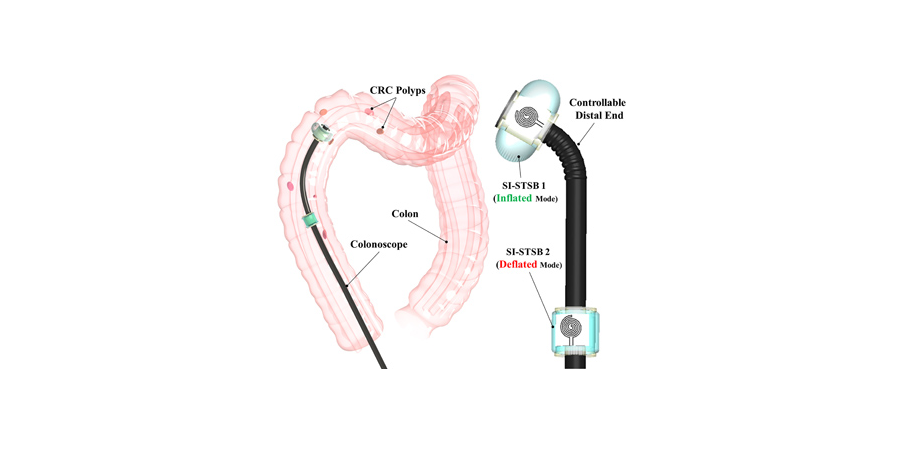
The printed strain sensors are used in soft tactile sensing devices for robotic surgery research. One application integrates the sensors into inflatable silicone structures mounted on a colonoscope, where deformation of the liquid-metal traces can be used to measure mechanical response as the device contacts tissue.
Direct-write fabrication makes it easier to iterate on sensor geometry because changes can be made in the toolpath instead of requiring new fabrication tooling for every design.